Engineering journal
What we found, and what it cost to find it.
Field reports from building the stack: scheduling, control loops, transport bugs, and the measurements behind the claims.
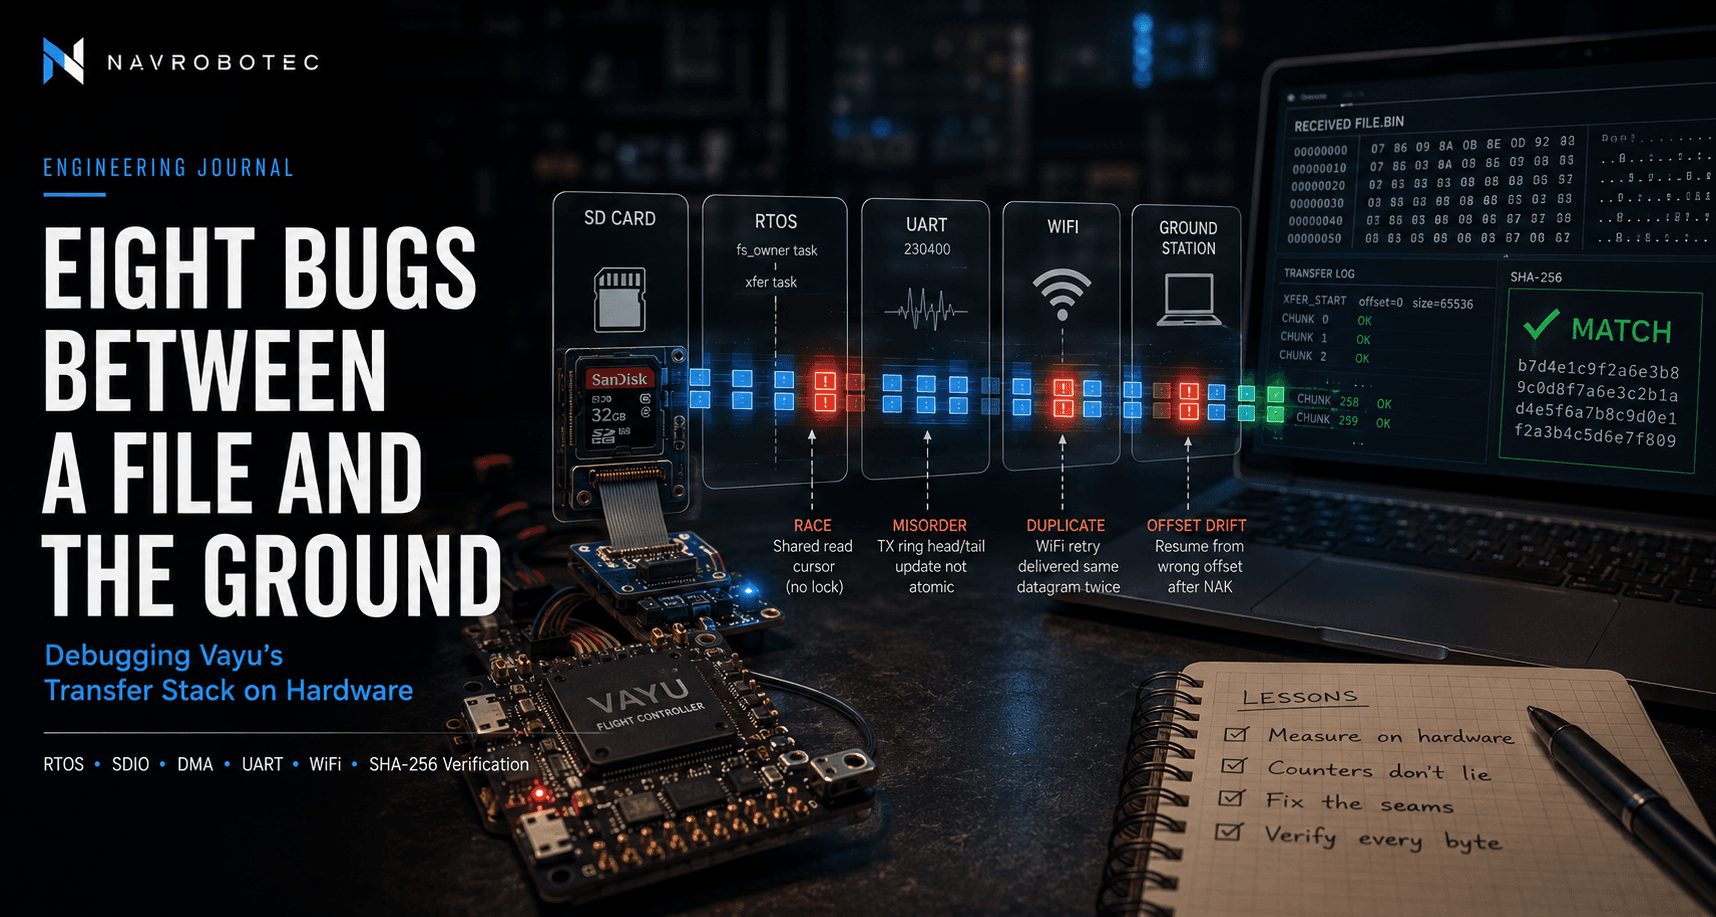
Eight Bugs Between a File and the Ground: Debugging Vayu’s Transfer Stack on Hardware
I wanted to copy a file off the flight controller’s SD card and get the same bytes back. Small files worked; anything past a kilobyte stalled or came back subtly wrong, non-deterministically. The hunt that followed: an isolation ladder that exonerated the SD card, a plausible theory ruled out by measuring instead of guessing, and two bugs with the exact same shape. Eight fixes later, the round-trip is byte-perfect to 64 KB.
Read itCutting the Cable: Reading Vayu’s First Wireless Rig Log
We had logged the flight controller on the bench before — but always down a USB cable, which is exactly what kept it pinned to the bench. A new UDP/WiFi telemetry bridge cut that cable and let the airframe move freely on a rig for the first time. A frame-by-frame read of that first untethered log: the transport, an attitude loop that shakes itself apart under its own feedback, and the sensors and telemetry bugs underneath.
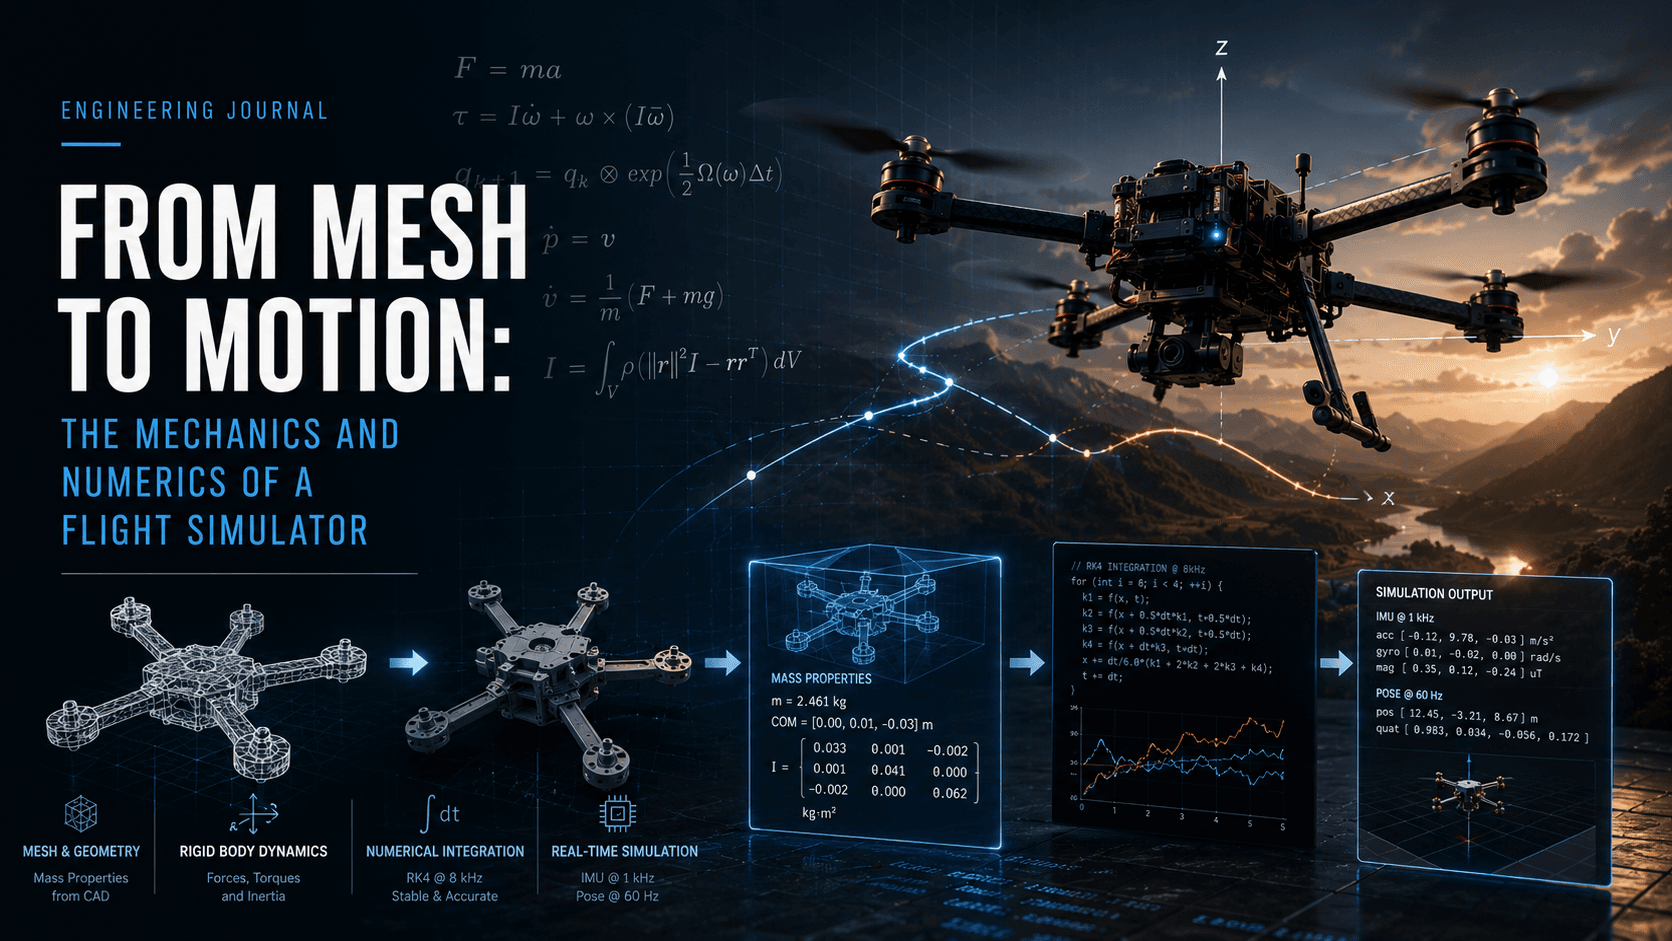
From Mesh to Motion: The Mechanics and Numerics of a Flight Simulator
vsim_d is the physics daemon that flies Vayu’s real firmware in software. A field report from the seam where Newton–Euler rigid-body mechanics meets RK4, quaternion drift, impulse contact, and a hard-real-time loop — including the cleanest way I know to turn a triangle mesh into an inertia tensor, and the bugs where the physics was right but the numerics (or the systems) lied.
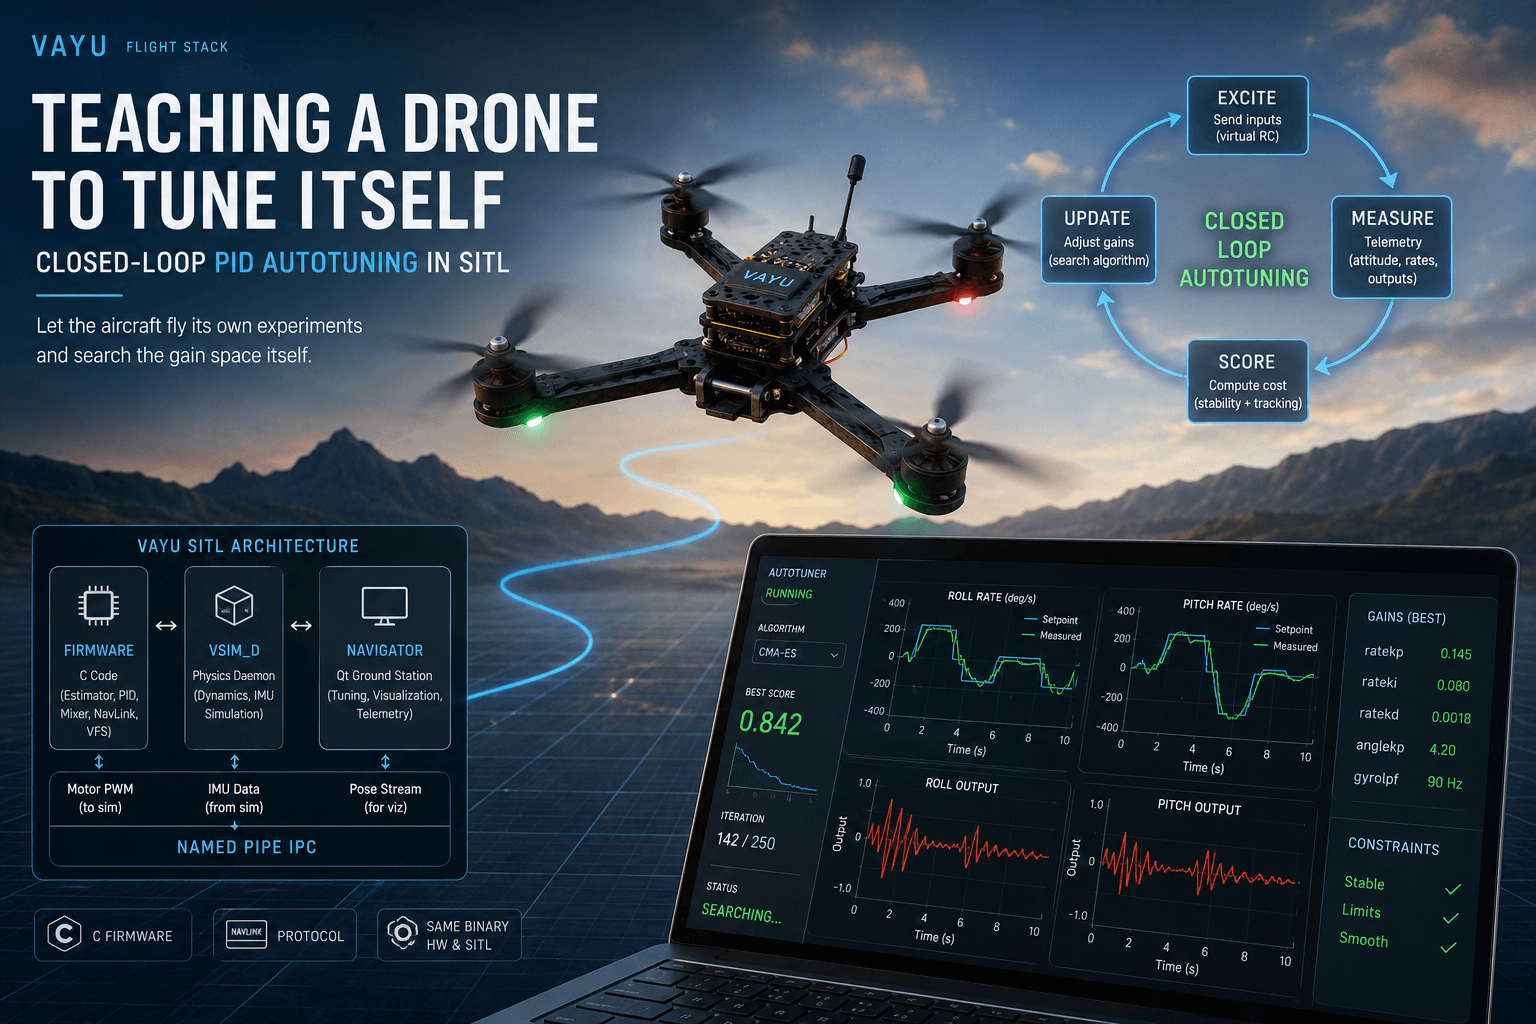
Teaching a Drone to Tune Itself: Closed-Loop PID Autotuning in SITL
We built a closed-loop PID autotuner that flies its own experiments in simulation and searches the gain space — eight optimizers, a chatter-aware cost, and two failure modes that looked solved but weren't. A deep dive into the system, the algorithms, and the fixes.
Benchmarking VAIOS Against FreeRTOS and Zephyr
We measured our in-house real-time operating system against FreeRTOS and Zephyr on the same flight-controller hardware — scheduling, IPC, memory, timing, and footprint. Here is the full set of results.
The Need for Indigenous Flight Control Software in India
Why building drones isn't enough—and why India needs sovereign, zero-dependency intelligence to drive its autonomous future.